Event-Based Prediction Model for Multiple Objects and 3D Annotations in Logistics Scenario
My MSc thesis, "Event-Based Prediction Model for Multiple Objects and 3D Annotations in Logistics Scenario", for the UPM Master's in Robotics and Automation, carried out at Technische Universität Dortmund: event-based object prediction and 3D annotations for logistics. It is a thesis, not a paper.
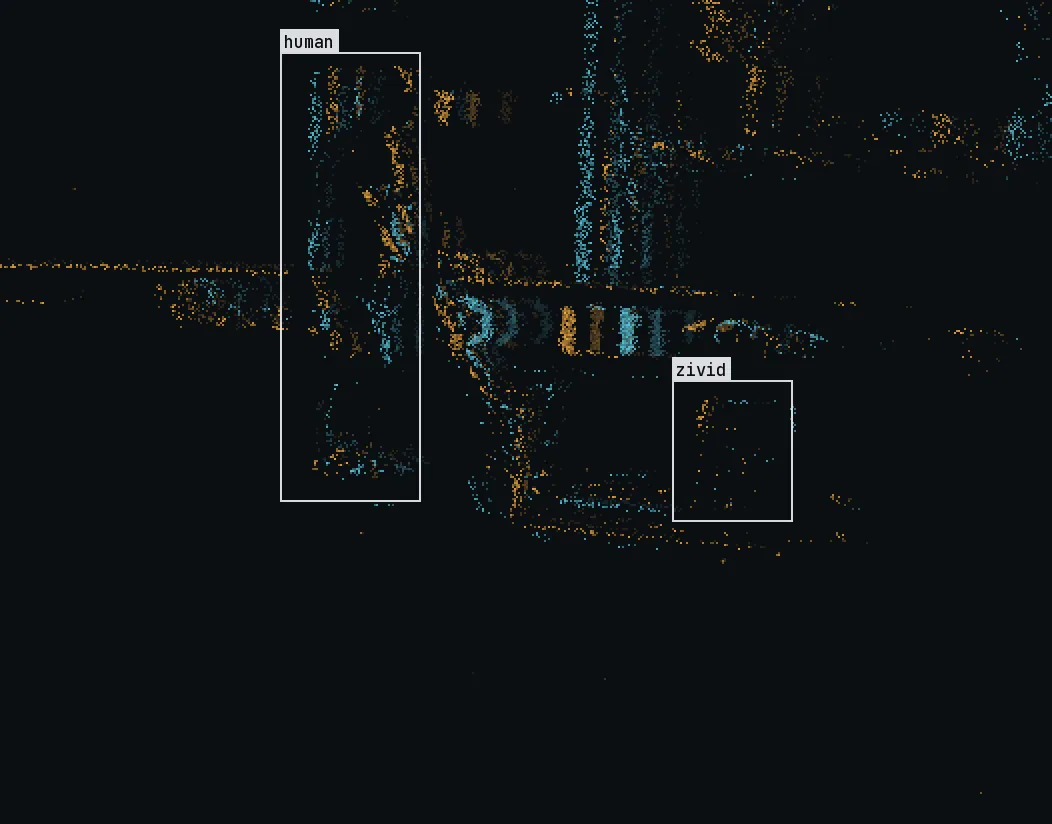
The thesis recording, replayed as events
An event camera has no frames. Each pixel reports on its own the moment its brightness changes: an ON event when it gets brighter, an OFF event when it gets darker.
- Amber
- ON events: the pixel got brighter.
- Cyan
- OFF events: the pixel got darker.
- Boxes
- The model's detections in the thesis video: a person (human) and a box (zivid).
These events are reconstructed from my thesis visualisation, not read from the raw sensor files: in each frame of that video, brighter and darker pixels became ON and OFF events, spread evenly over the frame's time. The boxes are the ones drawn in the same video. Timing follows its 12 frames a second, so it is coarser than the sensor's own clock.
298,882 events, 8.33 s, 526 × 412 px